{ "@context": "https://schema.org", "@type": "WebPage", "@id": "/posts/figure-8", "name": "Figure 8 LEGO Robot Driving Challenge", "description": "A quick challenge for speedier teams: program a robot to drive around four chair legs in a figure 8. Explore different ways of making a two-wheeled robot turn.", "url": "/posts/figure-8", "inLanguage": "en", "mainEntity": { "@type": "Article", "headline": "Figure 8", "description": "A quick challenge for speedier teams: program a robot to drive around four chair legs in a figure 8. Explore different ways of making a two-wheeled robot turn.", "image": "https://cdn.prod.website-files.com/65b933e10656d98773dd067c/6739ec3a67cf85fd63c6f800_IMG_8854.avif", "datePublished": "2020-05-19", "author": { "@type": "Person", "name": "" } }, "breadcrumb": { "@type": "BreadcrumbList", "itemListElement": [ {"@type": "ListItem", "position": 1, "name": "Home", "item": "/"}, {"@type": "ListItem", "position": 2, "name": "Articles", "item": "/articles"}, {"@type": "ListItem", "position": 3, "name": "Figure 8", "item": "/posts/figure-8"} ] } }

Are we missing anything?
Let us know!

Thank you! Your submission has been received!
Oops! Something went wrong while submitting the form.

Figure 8

May 2020

Here is a simple idea that I often use when I need a quick challenge for speedier teams to work on while they are waiting for the rest of the class. For example, when I've asked all teams to make a standard build such as the Robot Educator Model.
The challenge

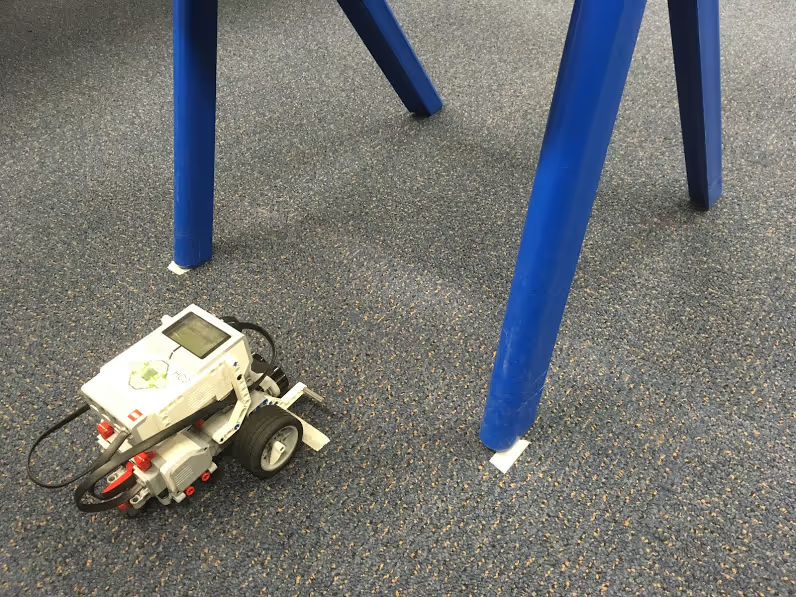
Program a robot to drive around four chair legs in a "figure 8" pattern.

Equipment required

A four-legged chair or equivalent.

As can be seen in the photo, I usually use a few pieces of tape to mark the starting line and the position of the chair legs.

Teacher notes

Although this is of course a fairly straight-forward challenge, I find it useful for exploring different ways of making a two-wheeled robot turn, including:

  • turning on the spot (with both wheels turning in opposite directions),
  • one wheel fixed, or
  • both wheels moving forward but at different power levels.

Having successfully completed a single "figure 8", I like to challenge teams to see how many times their robot can perform the circuit without intervention. This raises questions of reliability and repeatability, and leads nicely into a discussion around the limitations of dead reckoning. For more on this topic, see Why Doesn't My Robot Drive Straight?

Related Articles

Up Arrow
FEEDBACK
Up ArrowUp Arrow